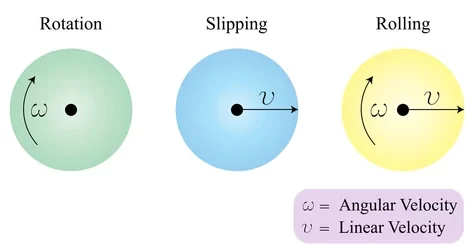
The relationship between linear velocity and angular velocity is v = ωr. The linear (tangential) velocity of any point on a rotating body equals its angular velocity multiplied by its distance from the axis of rotation. For the formula to work, ω must be in radians per second (rad/s) and r in metres (m), which gives v in metres per second (m/s). The SI unit of linear velocity is m/s; the SI unit of angular velocity is rad/s.
That one line hides two ideas students lose marks on: ω has to be converted out of rpm first, and every point on the same rigid body shares one ω but has its own v. The rest of this page builds the relation from scratch and then puts both traps to work in numbers.
Angular displacement and why radians make v = ωr work
Take a particle moving on a circle of radius r. In some time it travels an arc of length s and sweeps an angle θ at the centre. The arc-length equation ties the two together:
s = rθ
This is only true when θ is in radians. A radian is defined as the angle for which the arc length equals the radius, so one full circle is 2π rad and the constant of proportionality between s and θ is exactly r, with nothing left over. Put θ in degrees and you are forced to carry a π/180 factor everywhere. That is the whole reason radians are the working unit in rotational mechanics, and the reason v = ωr has no stray constant in it.
- Angular displacement θ – angle swept about the axis, in radians (rad).
- Angular velocity ω = dθ/dt – rate of sweeping that angle, in rad/s.
- Angular acceleration α = dω/dt – rate of change of ω, in rad/s².
Note that the radian is a ratio of two lengths, so it is dimensionless. That is why rad/s × m gives m/s and the units of v = ωr come out right.
Derivation of v = ωr
Start from the arc-length relation for a particle at a fixed radius r:
s = rθ
Differentiate both sides with respect to time. Since r is constant for a point on a rigid rotating body, it comes out of the derivative:
ds/dt = r (dθ/dt)
Now ds/dt is the rate at which the particle covers arc length, which is its linear speed v along the path. And dθ/dt is ω by definition. So:
v = ωr
Differentiate once more and you get the companion relation for tangential acceleration:
dv/dt = r (dω/dt), so at = αr
The direction matters too. v here is the tangential velocity: it points along the tangent to the circle, at right angles to the radius, and it keeps changing direction even when the speed stays fixed. That changing direction is exactly what centripetal acceleration accounts for.
Mistake 1: ω must be in rad/s, not rpm
Machine data is almost always quoted in revolutions per minute. A motor nameplate says 1440 rpm, a fan says 350 rpm, a lathe spindle says 600 rpm. None of those numbers can go straight into v = ωr. Convert first:
ω = 2πN/60 rad/s, where N is the speed in rpm.
The logic is short: one revolution is 2π rad, and one minute is 60 s, so N rev/min = 2πN rad per 60 s.
Worked example 1: belt speed on a pulley
A pulley of radius r = 0.40 m turns at N = 300 rpm. Find the linear speed of the belt on its rim.
- ω = 2πN/60 = 2π × 300 / 60 = 10π = 31.42 rad/s
- v = ωr = 31.42 × 0.40 = 12.57 m/s
Sanity check: 300 rpm is 5 revolutions per second, and one revolution covers a circumference of 2π × 0.40 = 2.513 m, so the belt moves 5 × 2.513 = 12.57 m in a second. The two routes agree.
Student tip: if you had dropped the conversion and used 300 straight into v = ωr, you would have got 120 m/s, off by a factor of 2π/60 and physically absurd for a workshop pulley. A quick “is this speed believable?” check catches it every time.
Mistake 2: same ω, different v
This is the single most important consequence of v = ωr. On a rigid rotating body, every particle sweeps the same angle in the same time, so ω is identical everywhere on the body. But r is not identical, so v grows in direct proportion to distance from the axis.
Worked example 2: one disc, two radii
A disc rotates at 120 rpm. Find v at r₁ = 0.10 m and at r₂ = 0.25 m.
- ω = 2π × 120 / 60 = 4π = 12.57 rad/s, the same for both points.
- v₁ = 12.57 × 0.10 = 1.26 m/s
- v₂ = 12.57 × 0.25 = 3.14 m/s
The outer point moves 2.5 times faster, which is exactly the ratio of the radii, 0.25/0.10. Nothing about ω changed.
Three everyday versions of the same fact:
- Merry-go-round. A child sitting near the centre and a child at the rim complete a turn together, so they share ω. The one at the rim is travelling much faster and finds it far harder to hold on, because the grip has to supply a larger centripetal force.
- Ceiling fan. The blade root barely moves; the tip is doing tens of metres per second. Same ω, larger r.
- Lathe or grinding wheel. Cutting speed is a rim speed, so a larger workpiece diameter at the same spindle rpm means a higher cutting speed. This is why machinists drop the rpm as the diameter goes up.
Vector form: v = ω × r
The scalar relation gives magnitude only. The complete statement is a cross product:
v = ω × r
Here ω is the angular velocity vector, pointing along the axis of rotation in the sense given by the right-hand rule (curl the fingers of the right hand with the rotation; the thumb gives ω). The vector r is the position vector of the point from a point on the axis.
- Magnitude: |v| = ωr sin φ, where φ is the angle between ω and r. If r is measured perpendicular to the axis, φ = 90°, sin φ = 1 and you recover v = ωr.
- Direction: the cross product is perpendicular to both ω and r, which is precisely the tangential direction. So the vector form delivers the “velocity is tangent to the circle” result automatically instead of you having to state it.
- Order matters: ω × r and r × ω point opposite ways. Writing it the wrong way round reverses the motion.
Centripetal and tangential acceleration
A point on a rotating body can have two accelerations at once, and they are perpendicular to each other.
- Tangential acceleration at = αr – changes the speed. Zero when the body spins at constant rpm.
- Centripetal acceleration ac = v²/r = ω²r – changes the direction. Always points inward, towards the axis. Never zero while the body is turning.
The two forms of ac are the same thing: substitute v = ωr into v²/r and you get (ωr)²/r = ω²r.
Worked example 3: fan blade tip
A ceiling fan blade tip is at r = 0.60 m and the fan runs at 350 rpm. Find the tip speed and its centripetal acceleration.
- ω = 2π × 350 / 60 = 36.65 rad/s
- v = ωr = 36.65 × 0.60 = 21.99 m/s (about 79 km/h at the tip)
- ac = ω²r = 36.65² × 0.60 = 1343.2 × 0.60 ≈ 806 m/s²
- Cross-check with v²/r: 21.99² / 0.60 = 483.6 / 0.60 = 806 m/s². Same answer.
That is about 82g pulling outward on the blade material, which is why fan blades are riveted and balanced rather than clipped on.
Total acceleration is the vector sum
When the body is also speeding up, combine the two perpendicular components:
a = √(at² + ac²), at an angle φ from the radius where tan φ = at/ac.
Take a flywheel with α = 5 rad/s², a point at r = 0.30 m, at the instant ω = 10 rad/s:
- at = αr = 5 × 0.30 = 1.5 m/s²
- ac = ω²r = 100 × 0.30 = 30 m/s²
- a = √(1.5² + 30²) = √902.25 = 30.04 m/s², at tan⁻¹(1.5/30) = 2.86° from the inward radial line.
Notice how dominant the centripetal term is. Once a body is spinning at any useful speed, ac swamps at, and the total acceleration points almost straight at the axis.
Linear and angular quantities: the analogy table
Every equation of straight-line motion has a rotational twin with the same algebra. Learning the pairs saves memorising two sets of formulas.
| Linear quantity | Angular quantity | Connecting relation |
|---|---|---|
| Displacement s (m) | Angular displacement θ (rad) | s = rθ |
| Velocity v (m/s) | Angular velocity ω (rad/s) | v = ωr |
| Acceleration a (m/s²) | Angular acceleration α (rad/s²) | at = αr |
| Mass m (kg) | Moment of inertia I (kg·m²) | I = Σmr² |
| Force F = ma (N) | Torque τ = Iα (N·m) | τ = r × F |
| Momentum p = mv (kg·m/s) | Angular momentum L = Iω (kg·m²/s) | L = r × p |
| Kinetic energy ½mv² | Rotational KE ½Iω² | Rolling body: ½mv² + ½Iω² |
| Power P = Fv (W) | Power P = τω (W) | Same watts either way |
| v = u + at | ω = ω₀ + αt | Multiply the angular form by r |
The pattern is consistent: replace the linear symbol with its angular partner and the equation still holds. Moment of inertia is the one that behaves differently from its partner, because it depends on where the mass sits, not just how much there is.
Rolling without slipping: v = ωr again
A wheel rolling on the ground without skidding satisfies the same relation, now linking the speed of the centre of the wheel to its spin:
vcentre = ωR, where R is the wheel radius.
The condition holds because in one full turn the wheel lays down exactly one circumference of contact, 2πR, and no more. If v > ωR the wheel is skidding forward; if v < ωR it is spinning without gripping, like a scooter wheel on wet paint.
Worked example 4: a car wheel
A car travels at 54 km/h on wheels of radius 0.30 m. Find ω, the rpm, and the velocity of the top and the bottom of the wheel.
- v = 54 × 1000/3600 = 15 m/s
- ω = v/R = 15 / 0.30 = 50 rad/s
- N = 60ω/2π = 60 × 50 / 6.283 = 477.5 rpm
- Top of the wheel: 15 + (50 × 0.30) = 30 m/s, twice the car’s speed.
- Contact point: 15 − (50 × 0.30) = 0 m/s.
The contact point result surprises people, so it is worth stating plainly: in rolling without slipping, the point of the wheel touching the road is instantaneously at rest. Its forward translational velocity of +15 m/s and its backward rotational velocity of −15 m/s cancel exactly. That is what “without slipping” means, and it is why the whole wheel can be treated as rotating about the contact point at that instant. It is also why static friction, not sliding friction, acts on a rolling tyre.
Common errors to avoid
- Feeding rpm into v = ωr. Convert with ω = 2πN/60 first.
- Using degrees for θ. The relation s = rθ, and everything built on it, needs radians.
- Using diameter where the formula wants radius. A 500 mm pulley usually means diameter, so r = 0.25 m.
- Assuming a faster-moving rim point has a larger ω. It does not; ω is shared, only r differs.
- Forgetting that ac exists at constant speed. Constant speed on a circle still means changing velocity.
- Mixing units of length. Keep r in metres if you want v in m/s.
References
- NCERT Physics – Motion in a Plane and Systems of Particles and Rotational Motion, Class 11.
- NPTEL, Engineering Mechanics lecture series on kinematics of rigid bodies.
FAQs
What is the relationship between linear velocity and angular velocity?
Linear velocity equals angular velocity times the radius: v = ωr. The linear or tangential velocity of a point on a rotating body is its angular velocity in rad/s multiplied by its perpendicular distance from the axis in metres, giving v in m/s. In vector form it is v = ω × r.
What is the SI unit of linear velocity and angular velocity?
The SI unit of linear velocity is metre per second (m/s). The SI unit of angular velocity is radian per second (rad/s). Because the radian is a ratio of two lengths it is dimensionless, so rad/s multiplied by metres gives m/s directly in v = ωr.
How do you convert rpm to rad/s?
Use ω = 2πN/60, where N is the speed in revolutions per minute. One revolution is 2π radians and one minute is 60 seconds. For example, 300 rpm gives ω = 2π × 300/60 = 31.42 rad/s. Never substitute rpm straight into v = ωr.
Do all points on a rotating body have the same linear velocity?
No. Every point shares the same angular velocity ω, because the whole body sweeps the same angle in the same time, but linear velocity is v = ωr, so points farther from the axis move faster. On a disc at 120 rpm, a point at 0.25 m moves at 3.14 m/s while a point at 0.10 m moves at 1.26 m/s.
Why is v = ωr used for a rolling wheel?
For rolling without slipping, the wheel lays down exactly one circumference per revolution, so the centre’s speed is v = ωR. The top of the wheel then moves at 2v and the contact point is instantaneously at rest, which is why a rolling tyre experiences static friction rather than sliding friction.